|
Chang Shi 「施畅」 I am a Ph.D. student at UT Austin. My research focuses on developing efficient robot learning methods that are scalable, generalizable and deployable, from diverse data including but not limited to expert demonstrations, suboptimal trajectories, in-the-wild videos, and heuristics. I have the long-term vision that embodied AI agents can help humans with daily chores, through either autonomous or semi-autonomous solutions. Recently, I am working on imitation learning and controllable representation learning for world models. Previously, I was a Master's student at the Robotics Institute at Carnegie Mellon University, working with Prof. Howie Choset and Prof. John Galeotti on biomedical robotics. I received my Bachelor's degree in Computer Science from Renmin University of China. I also worked with Prof. Andrea L. Bertozzi on ego-motion classification of body-worn videos as a visiting undergraduate scholar at UCLA. In my spare time, I enjoy playing piano, tennis and skateboarding. |

|
News
|
 I will attend
Research(* denotes equal contribution)I'm interested in robot learning, imitation learning, reinforcement learning, and world models. Earlier, I worked on medical and surgical robotics. |
|
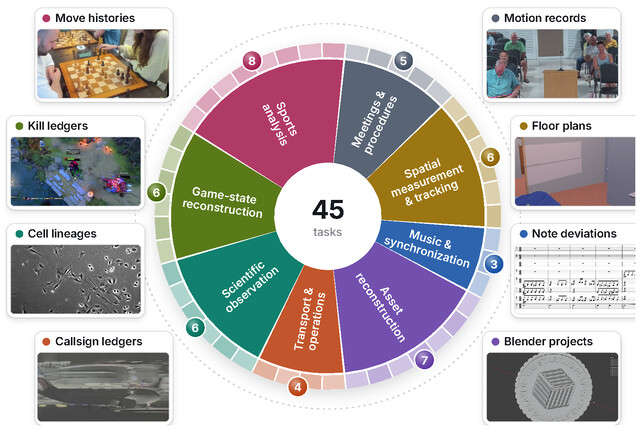
AgenticVBench-Omni: Evaluating Omnimodal Agents on Economically Valuable Work
Michelle Wang, Xiatao Sun, Jiaxuan Luo, Chong Peng, Su Wang, Chang Shi, ..., Xinyu Hu Under review at ICLR, 2027 |
|
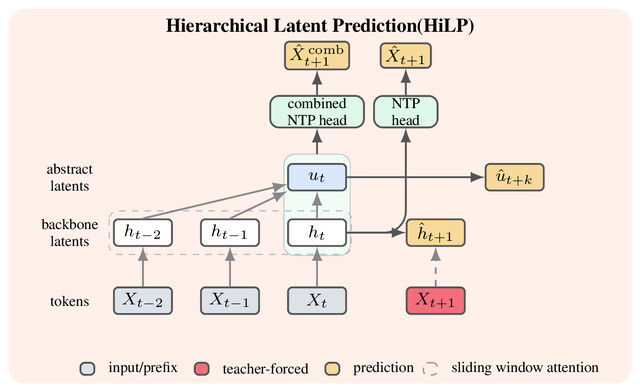
Hierarchical Latent Prediction for Language Models
Chang Shi, Tim Pearce, Manan Tomar, Siddhartha Sen, John Langford arXiv, 2026 arXiv |
|
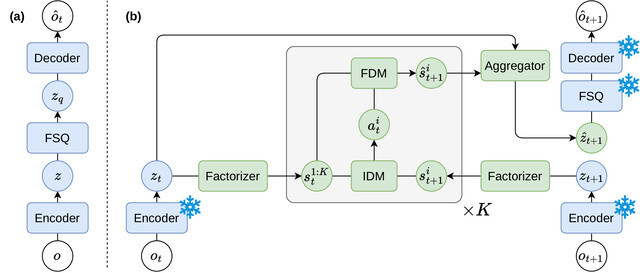
Factored Latent Action World Models
Zizhao Wang*, Chang Shi*, Jiaheng Hu, Kevin Rohling, Roberto Martín-Martín, Amy Zhang, Peter Stone ICML, 2026 paper / arXiv / NeurIPS 2025 workshop version |
|
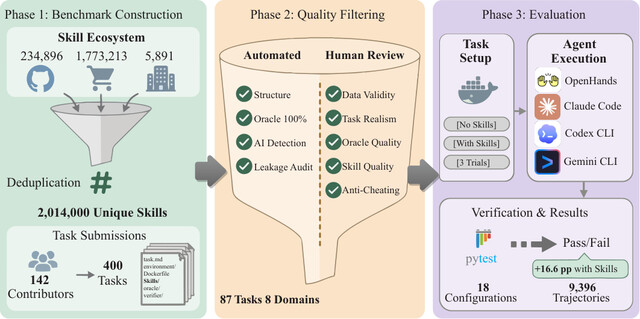
SkillsBench: Benchmarking How Well Agent Skills Work Across Diverse Tasks
Xiangyi Li, Yimin Liu, Wenbo Chen, ..., Chang Shi, ..., Dawn Song NeurIPS, 2026 arXiv |
|
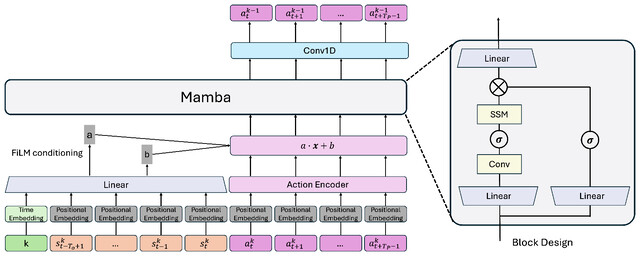
FastDP: Deployable Diffusion Policy for Fast Inference Speed
Chang Shi, Amy Zhang RLC Workshop on RL for Real Systems, 2025 paper |
|
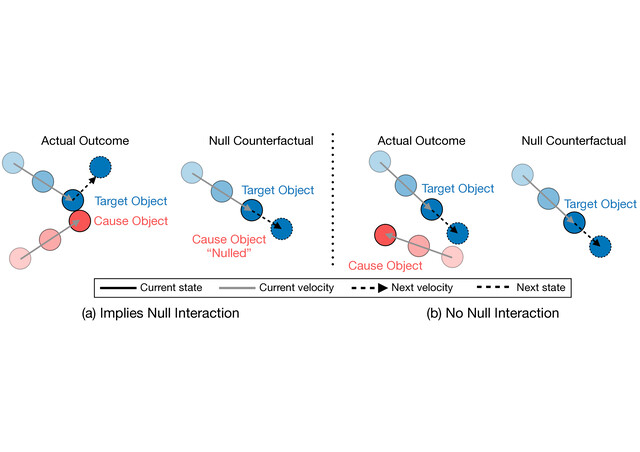
Null Counterfactual Factor Interactions for Goal-Conditioned Reinforcement Learning
Caleb Chuck, Fan Feng, Carl Qi, Chang Shi, Amy Zhang, Scott Niekum ICLR, 2025 arXiv |
|
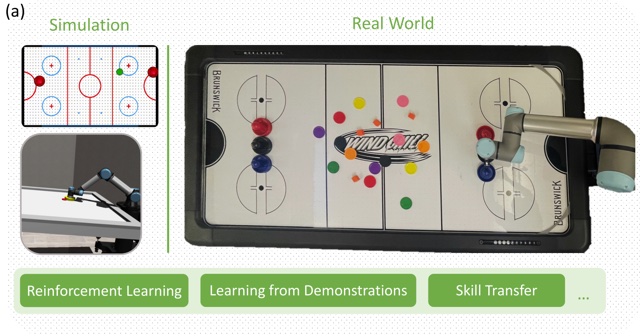
Robot Air Hockey: A Manipulation Testbed for Robot Learning with Reinforcement Learning
Caleb Chuck*, Carl Qi*, Michael J. Munje*, Shuozhe Li*, Max Rudolph*, Chang Shi*, Siddhant Agarwal*, Harshit Sikchi*, Abhinav Peri, Sarthak Dayal, Evan Kuo, Kavan Mehta, Anthony Wang, Peter Stone, Amy Zhang, Scott Niekum ICRA Workshops on Agile Robotics and Manipulation Skills, 2024 project page / arXiv |
|
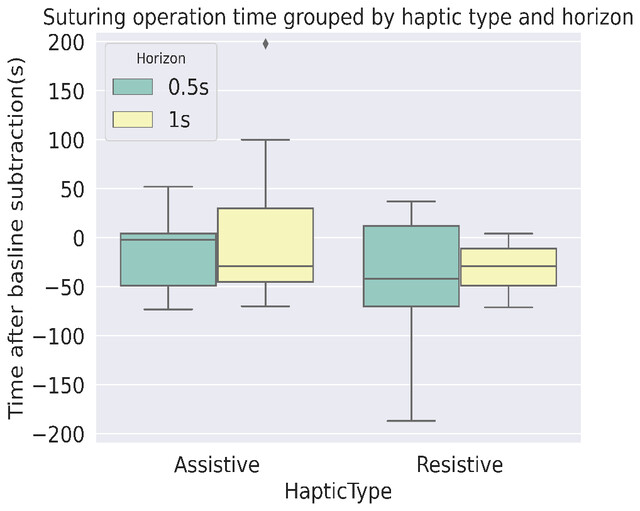
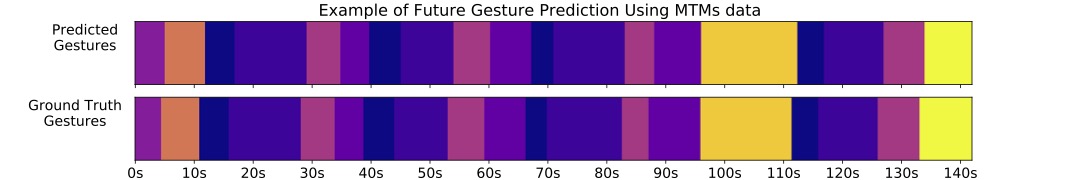
Haptic Guidance Using a Transformer-Based Surgeon-Side Trajectory Prediction Algorithm for Robot-Assisted Surgical Training
Chang Shi, Jonathan Madera, Heath Boyea, Ann Majewicz Fey IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), 2023 paper |
|
Recognition and Prediction of Surgical Gestures and Trajectories Using Transformer Models in Robot-Assisted Surgery
Chang Shi*, Yi Zheng*, Ann Majewicz Fey IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022 arXiv |
|
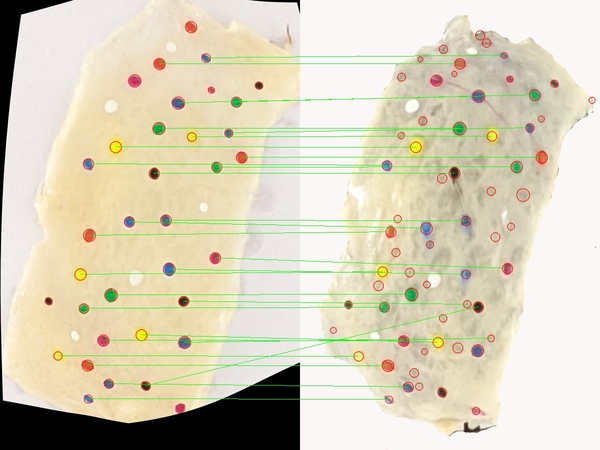
Non-rigid Cutaneous Tissue Deformation Estimation with Iterative RANSAC and TPS from Digital Images over Semi-ambiguous Artificial Markings
Chang Shi, Dustin P. DeMeo, Emma L. Larson, John M. Galeotti, Bryan T. Carroll Computer Assisted Radiology and Surgery (CARS), 2021 Iterative bidirectional blob matching and thin-plate-spline warping over artificial dye markers to model how tissue deforms between fresh specimens and frozen sections. |
|
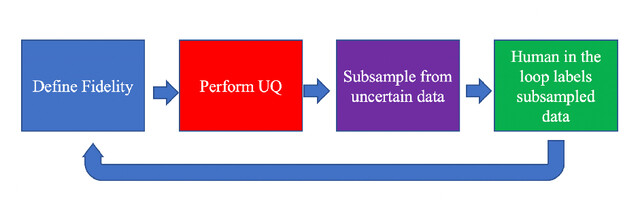
Uncertainty Quantification for Semi-supervised Multi-class Classification in Image Processing and Ego-motion Analysis of Body-worn Videos
Yiling Qiao, Chang Shi, Chenjian Wang, Hao Li, Matt Haberland, Xiyang Luo, Andrew M. Stuart, Andrea L. Bertozzi IS&T International Symposium on Electronic Imaging (EI), 2019 paper |
Honors & Awards
|
Service
|
|
Website template from Jon Barron. |